Projects
You can find detailed descriptions of my past and recent projects (done during my M.Sc. and Ph.D.), with codes, papers, videos and figures. You can filter by category.
-
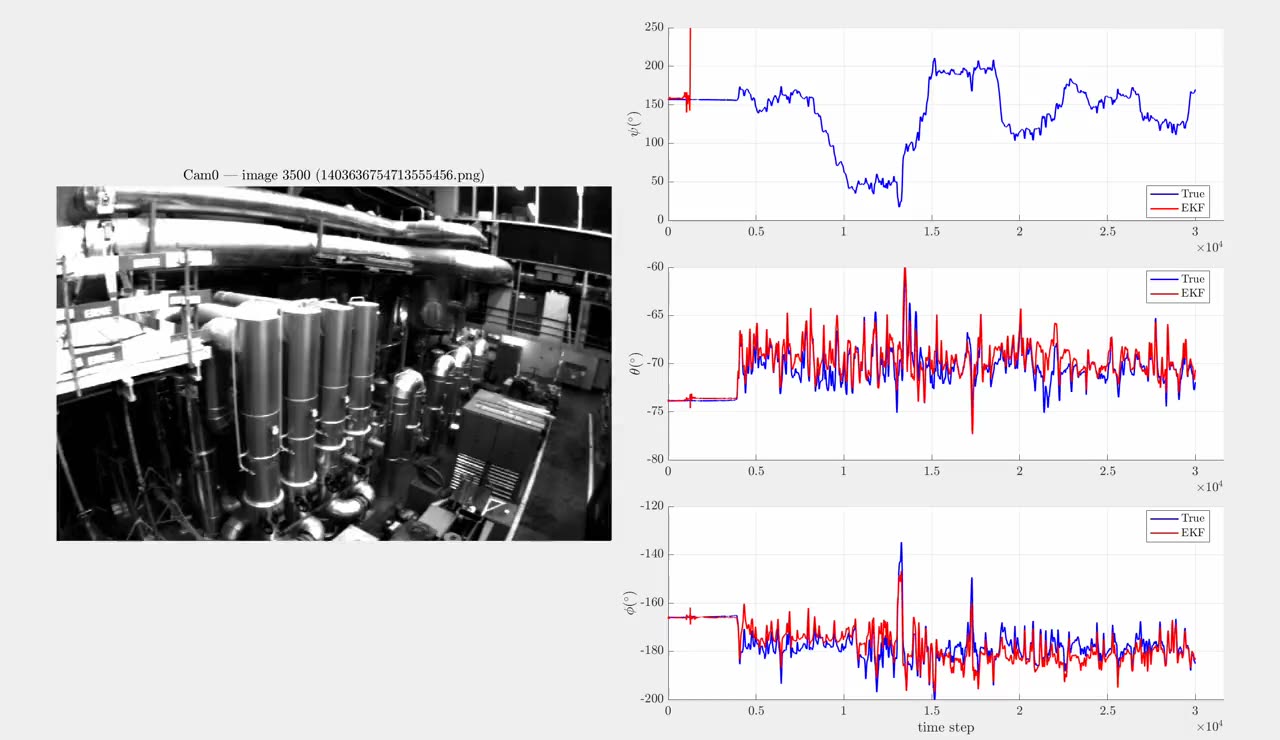
Attitude Estimation via EKF, UKF, ESEKF and EEKF
Four Bayesian filters for estimating orientation from IMU and magnetometer readings, compared under Gaussian and heavy-tailed noise and on the EuRoC MAV dataset, including a consistency-enforcing EKF built on semidefinite programming.
- State estimation
- Computer vision
-
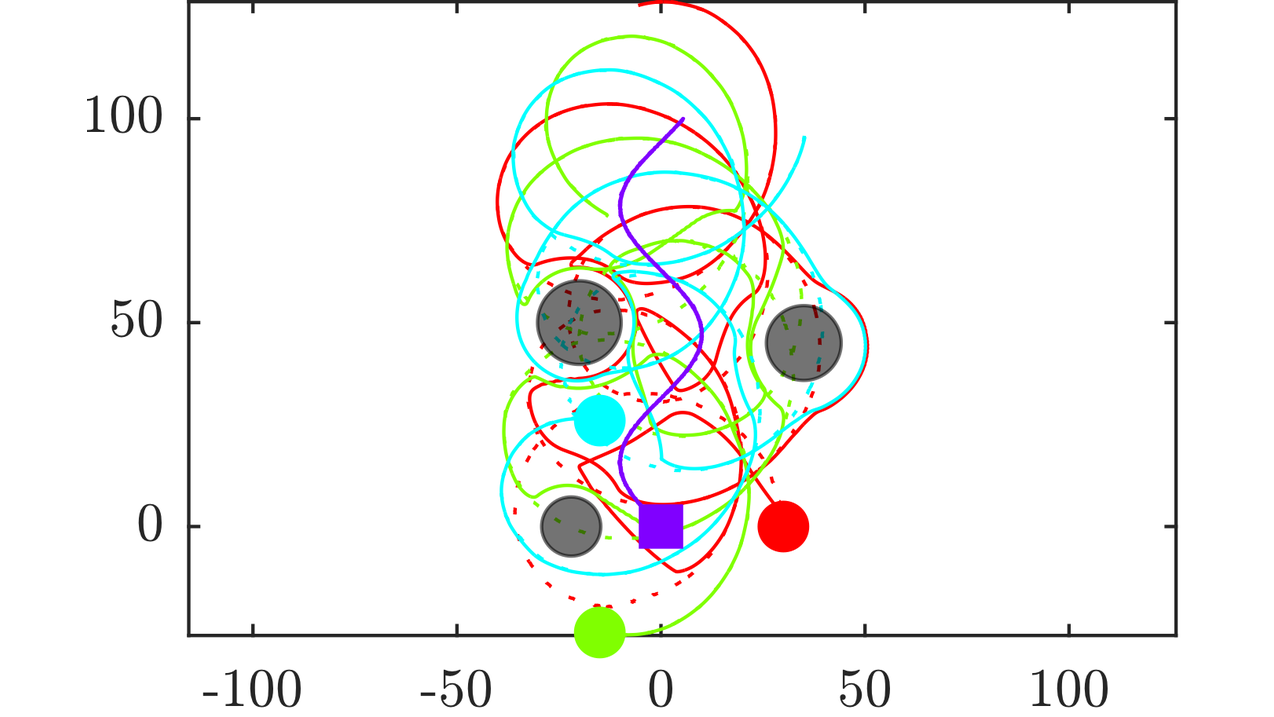
Target Tracking with Obstacle Avoidance
A team of agents with range-only sensors localizes and tracks a moving target in an optimal formation, rejecting external disturbances with an EKF and avoiding obstacles with a control barrier function safety filter.
- Multi-agent systems
- Control
- Convex optimization
-
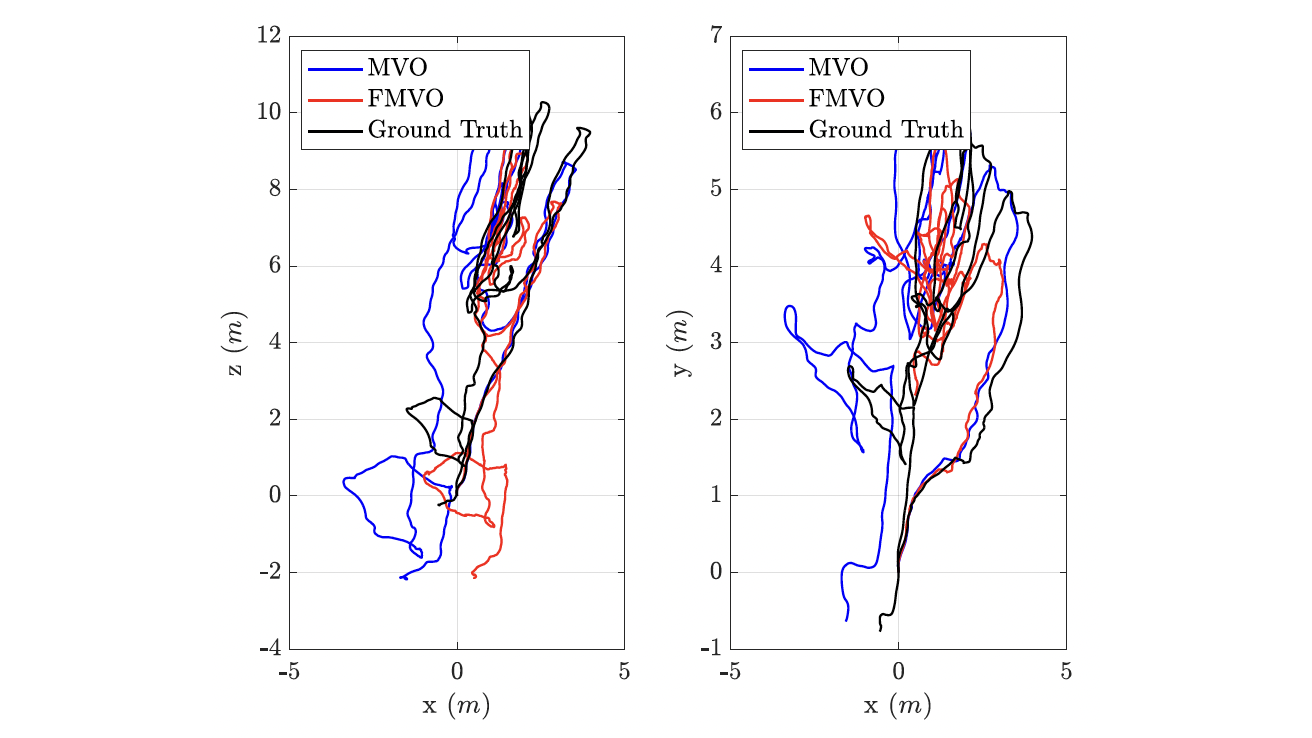
Fast Monocular Visual Odometry
A monocular visual odometry pipeline and a fast variant that extracts features only at keyframes, running about 20 times faster than the conventional approach on the EuRoC MAV dataset.
- Computer vision
-
Reachability of Neural Networks via Semidefinite Programming
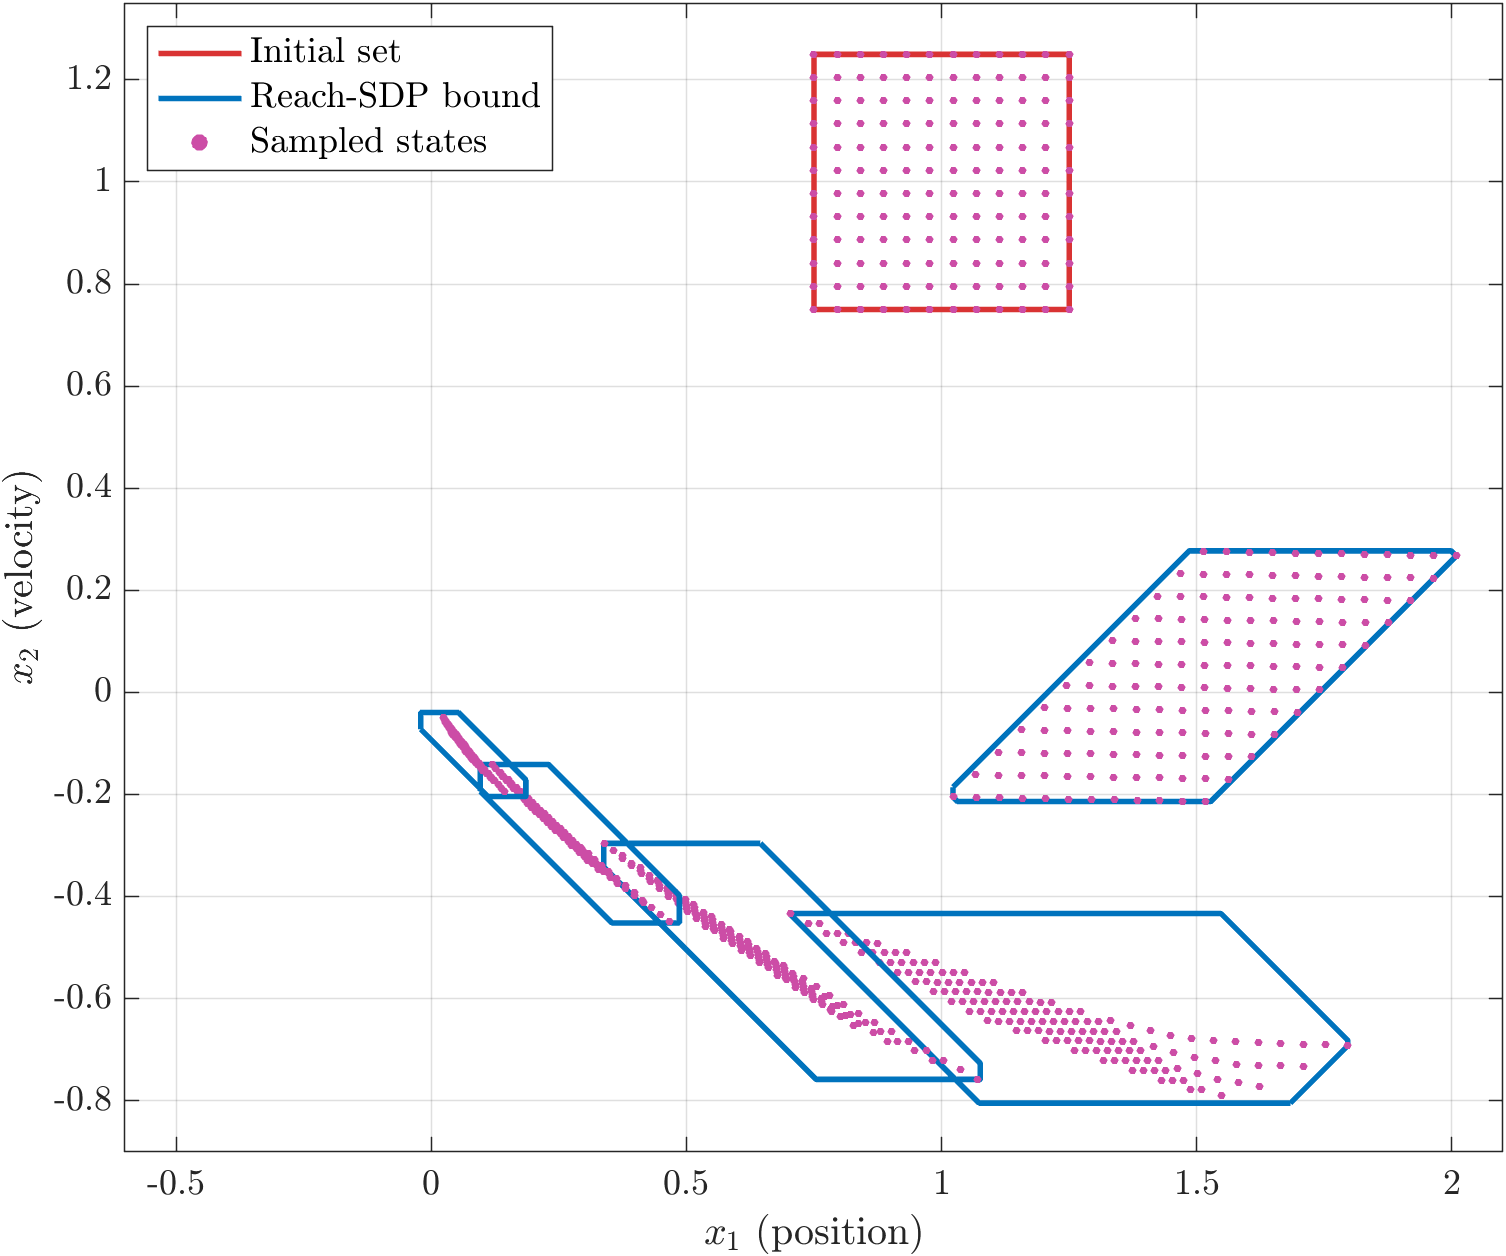
Bounding every state a neural-network-controlled system can reach, and confidence regions for the output of a network with a random input, by abstracting ReLU activations with quadratic constraints and solving semidefinite programs.
- Neural networks
- Convex optimization
-
Invariant EKF
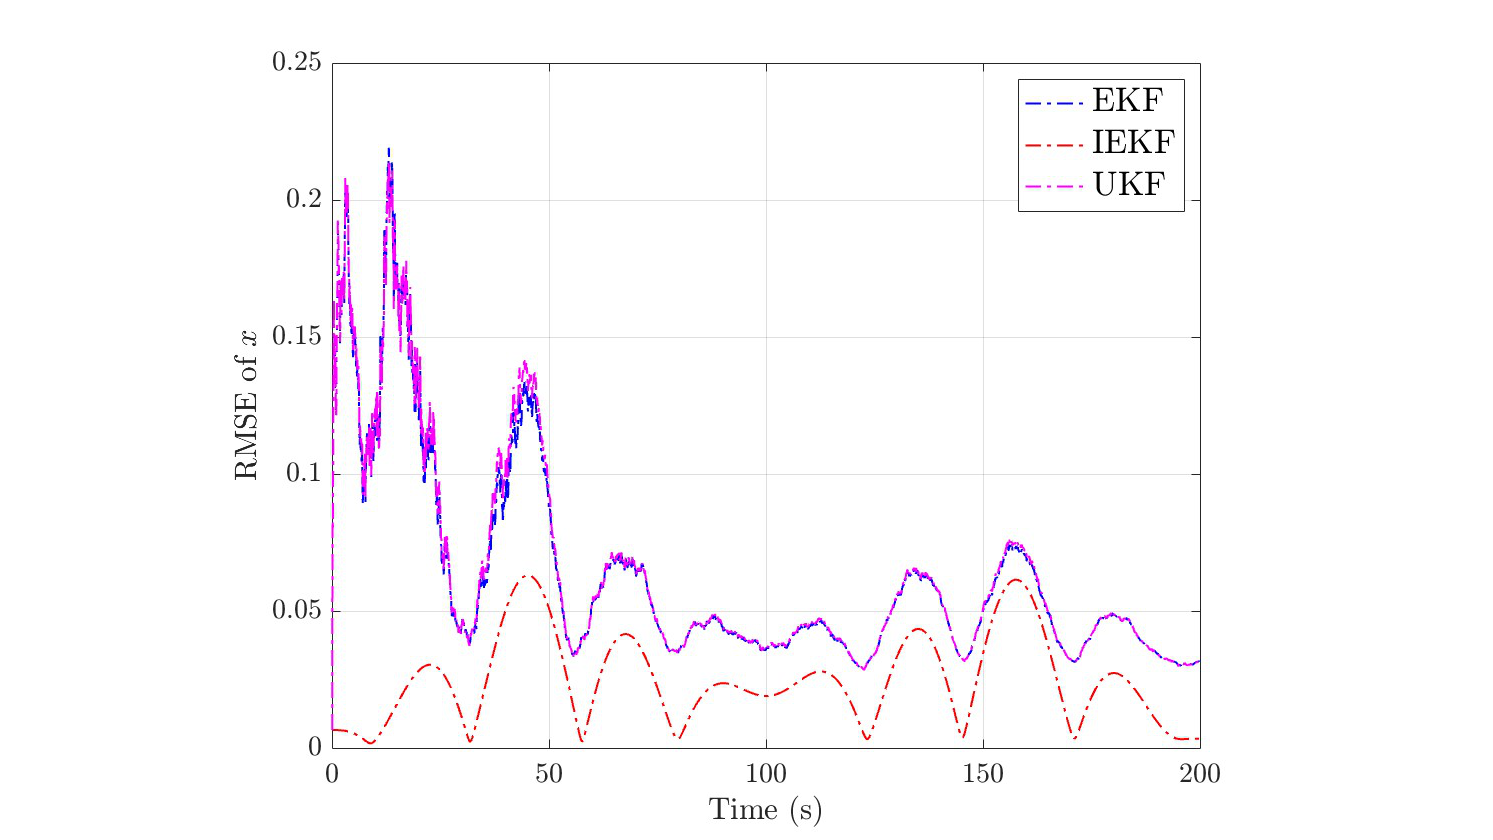
Invariant extended Kalman filters for a unicycle robot with and without additive disturbances, compared with the EKF and UKF.
- State estimation
-
Leader–Follower Signal Temporal Logic
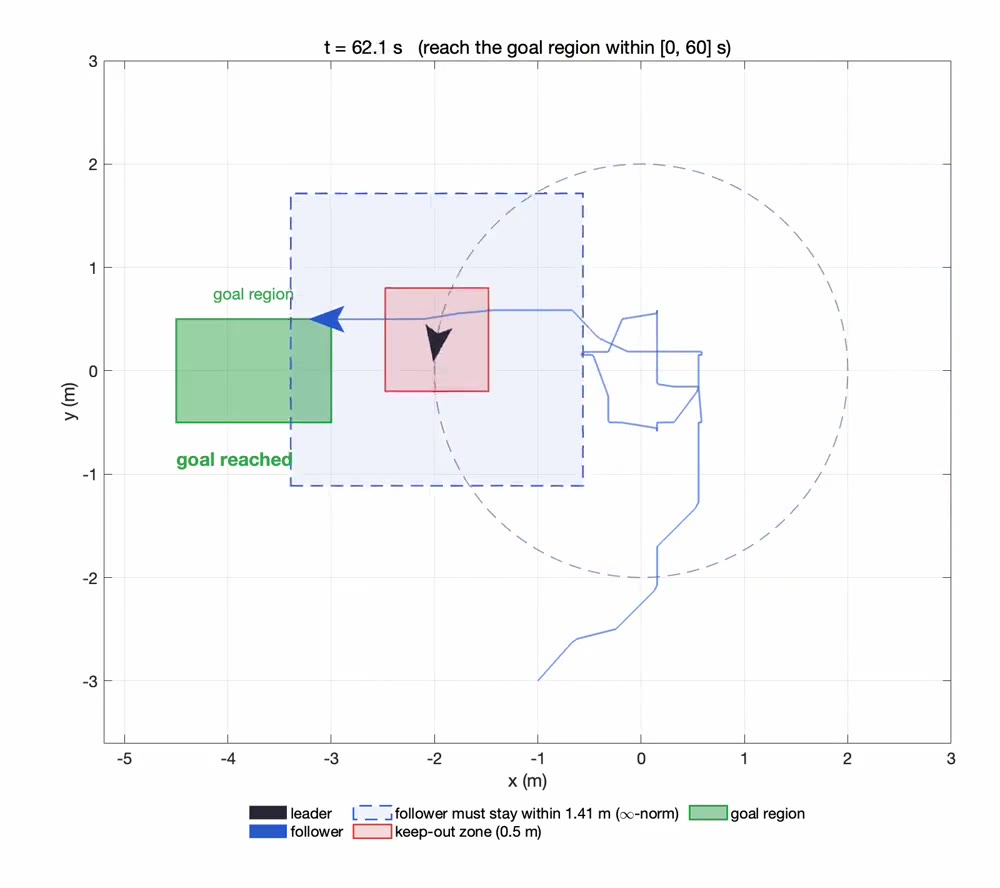
Planning the motion of a follower robot that must stay close to a moving leader without colliding with it, while visiting a goal region in time, by encoding the specifications in signal temporal logic and solving a mixed-integer program.
- Control
- Multi-agent systems
- Convex optimization
-
Visual-Inertial Odometry
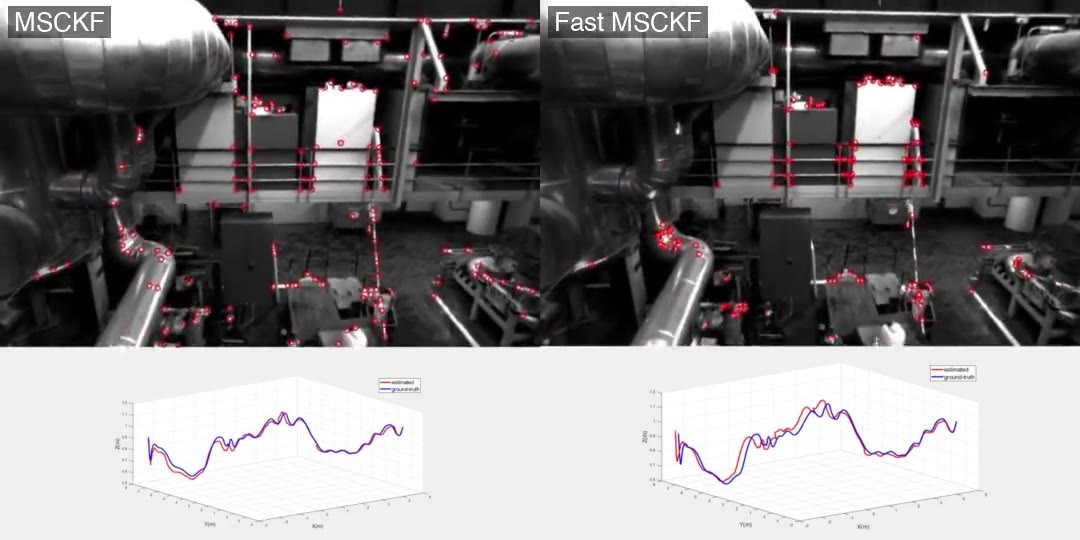
A faster multi-state constraint Kalman filter (Fast MSCKF) for estimating the pose of a camera-IMU system, several times faster and more accurate than the original MSCKF, tested on the EuRoC dataset and with a sensor setup built from scratch.
- State estimation
- Computer vision
-
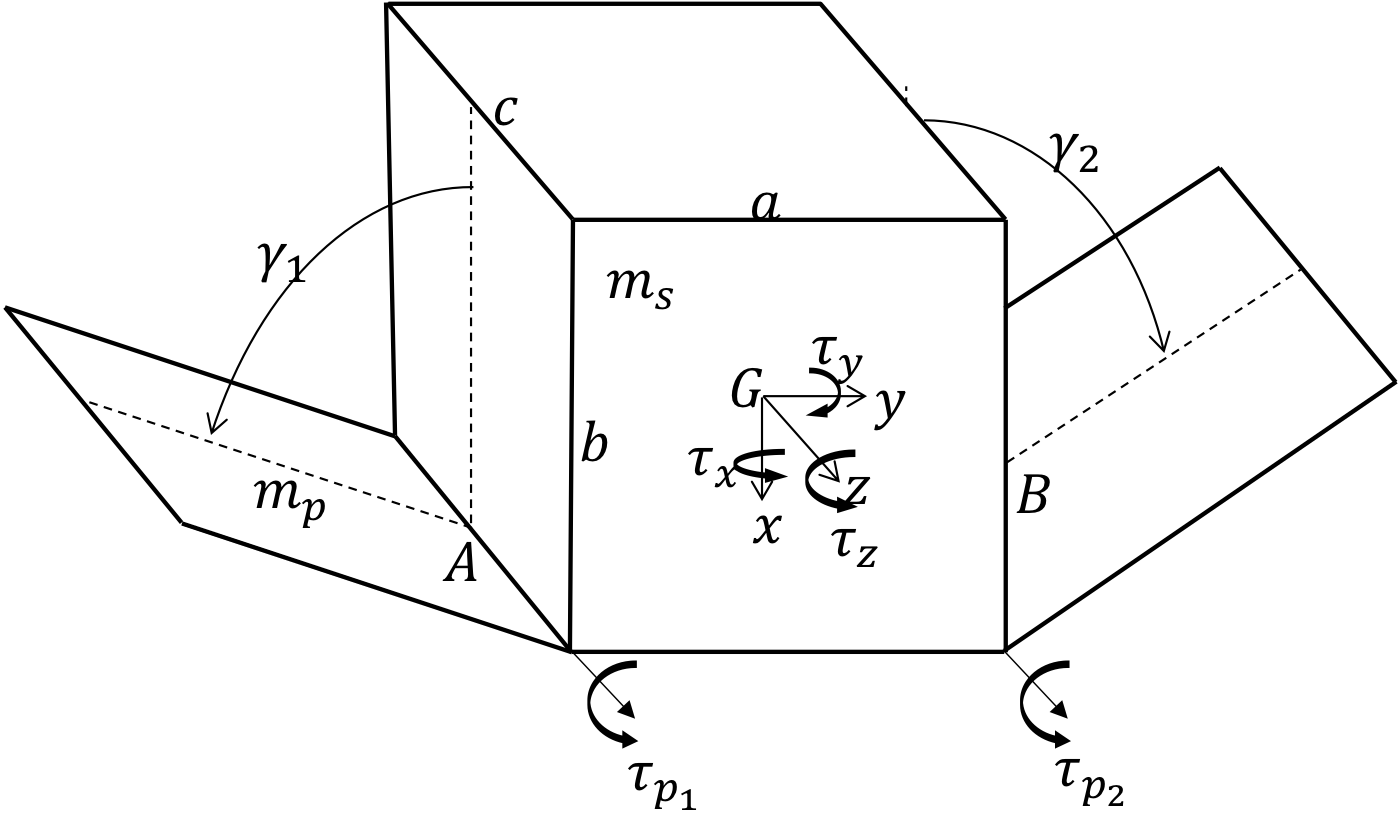
Volterra-Based Equations of Motion
An efficient form of Volterra’s equations of motion that treats the conserved momenta of ignorable coordinates as constraints, giving the minimum number of first-order equations for constrained and unconstrained multibody systems.
- Dynamics
-
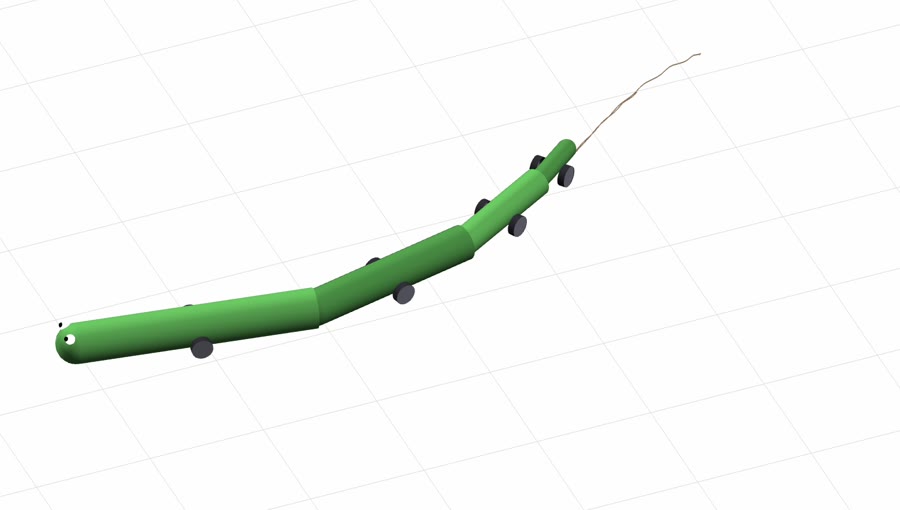
Snake Robot Equations of Motion
Equations of motion of a four-link wheeled snake robot with nonholonomic constraints, derived and solved with eight methods (from Lagrange multipliers to Kane and Gibbs–Appell) and compared in accuracy, run time and the size of the equations, with a 3D animation of the simulated motion.
- Dynamics
-
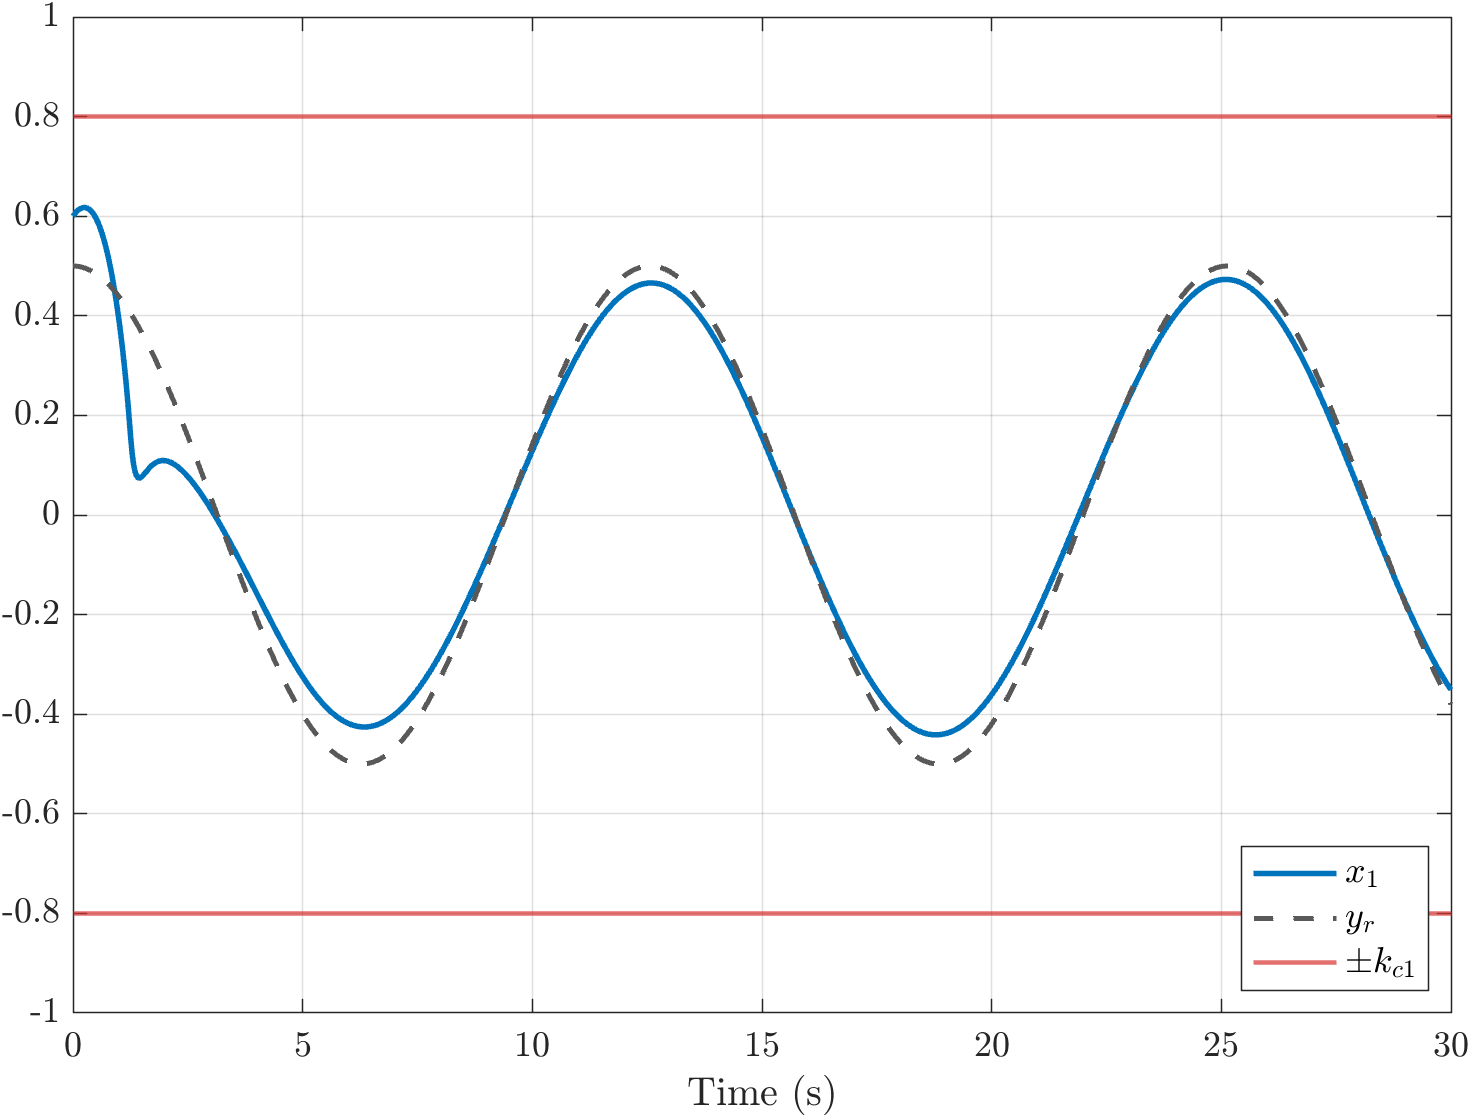
Barrier Lyapunov Functions for Constrained Adaptive Control
Adaptive tracking control of nonlinear systems whose states must stay within given bounds and whose control direction is unknown, using barrier Lyapunov functions and Nussbaum gains, extended to an external disturbance and an input delay.
- Control
-
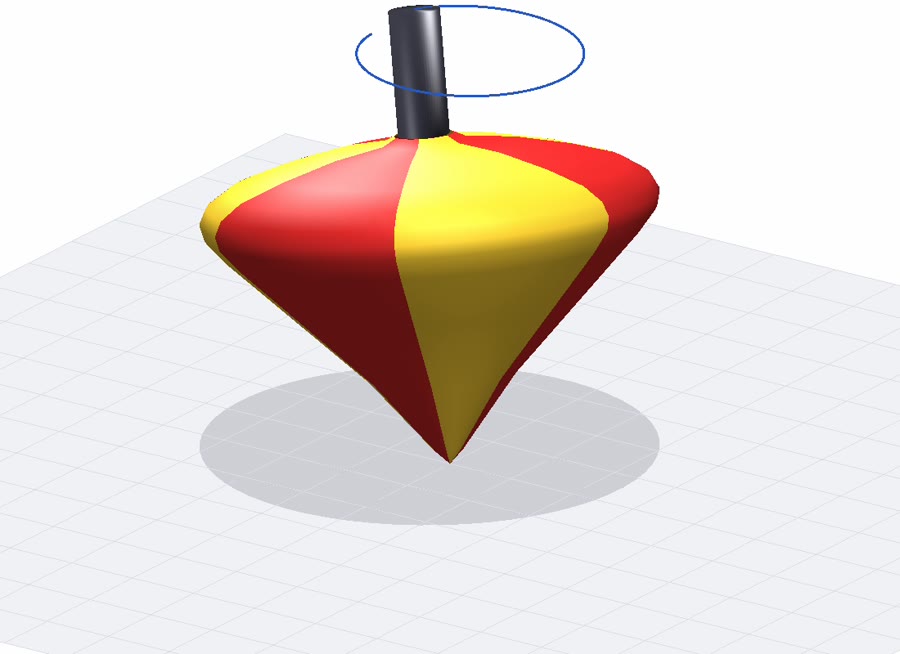
Spinning Top Equations of Motion
Equations of motion of a spinning top derived four ways (Lagrange and modified Lagrange, with Euler angles and with quaternions), compared in accuracy, run time, singularities and simplicity, with a 3D animation of the simulated motion.
- Dynamics
No projects in this category yet.